Building the world's leading lab for autonomous drone AI
Swarm builds the software that flies drones on their own. Our open benchmark finds the best flight models, and our lab puts them on real hardware. We are working towards physical AI: simulations built as twins of real places, where agents learn to fly drones.
- simulated worlds
- 8
- drone lab
- Andorra
- first on-site test
- Q1 2027
The missions our models fly
The exact missions our flight models train on and are scored on, before any of them touches a real drone.
From simulation to the field
Autonomy cannot be built in simulation alone. A model earns its place there first, then proves it on real hardware.
Simulation
 Simulation
Models fly thousands of scored missions in simulated worlds. Every score is public.
Lab
 Real flight
The drone Sentinel will fly, a DJI Matrice 4TD with its dock, is in our lab in Andorra. Our team tests there on real hardware.
On site
 Real hardware
First customer: solar plants in Greece, feasibility confirmed. The first on-site test is planned for Q1 2027.
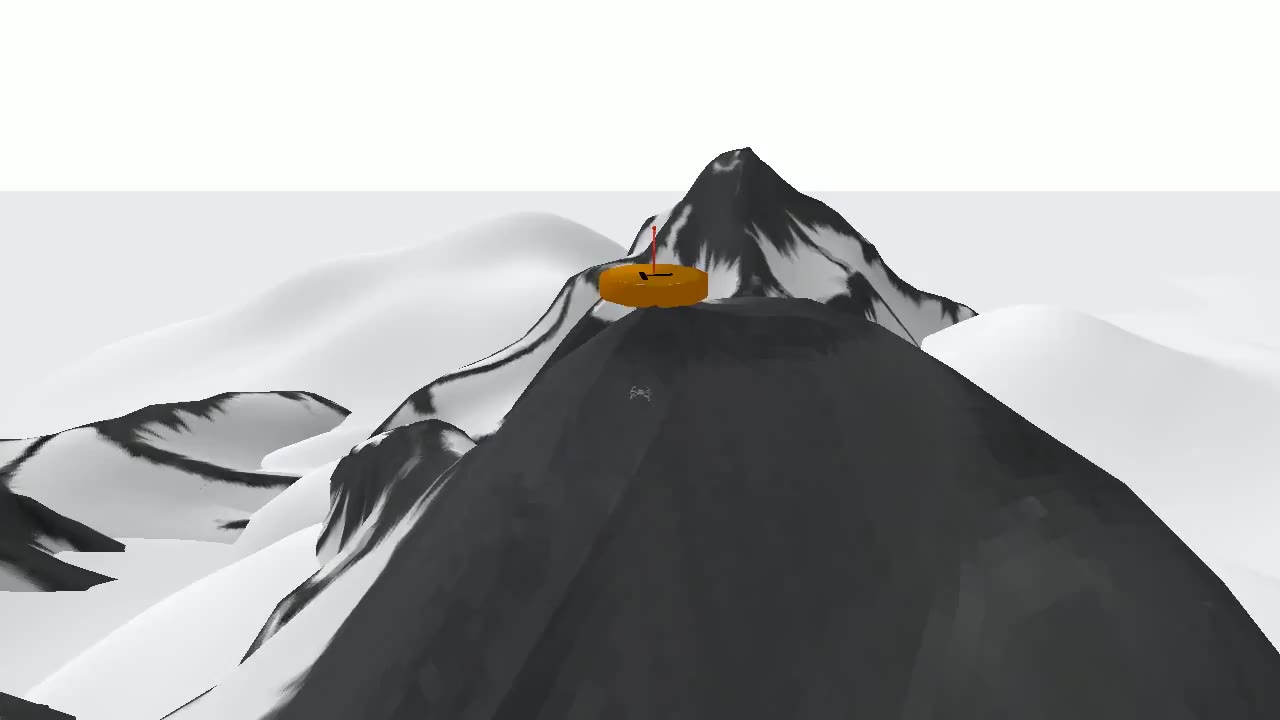
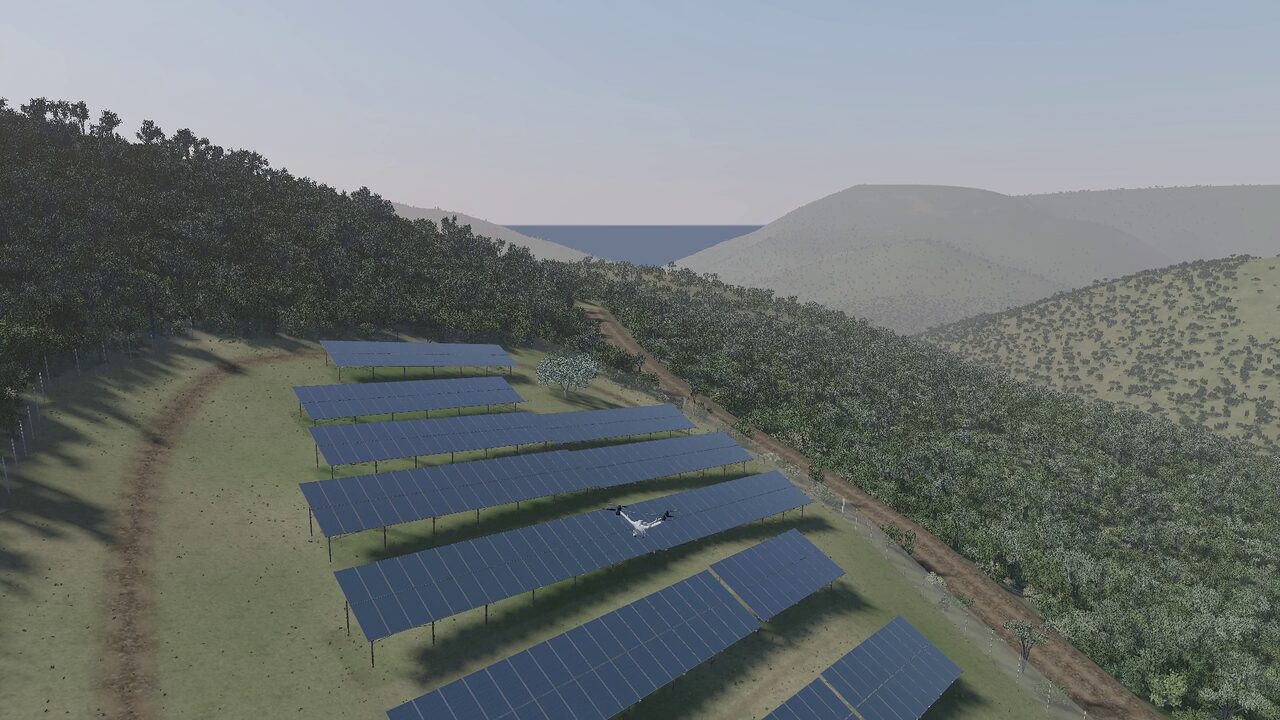
Eight worlds to fly in
Streets, trees, slopes, shelves and corridors. Each world asks a model something different, so it has to learn to fly, not to memorise a map.
 City
 Forest
 Mountain
 Village
 Warehouse
 Open terrain
 Office
 Solar park
The same method carries over to security patrols, search and rescue, infrastructure inspection, mapping and flight indoors, where there is no GPS and no sky.
What makes Swarm unique
An open competition, not one team
Developers around the world train flight models and compete on our benchmark. The network pays the ones that fly best.
Real-world twins, validated in our lab
We build simulations as twins of real places, so agents train fast. What they learn is then tested on real hardware in our drone lab.
Fitted to your fleet
We adapt the model to your airframes, sensors and limits, and deliver it to run on board or at the edge.
From concept to autonomy
Bring us a job your drones should do on their own. We take it from a first simulated mission to a model flying on your hardware.
Mission design
We turn your operation into a simulated mission with clear rules and a score.
Integration
We fit the flight AI to your drones, sensors, compute and software.
Field validation
Our lab takes the model through hardware tests and real flights before it goes live.
Open source
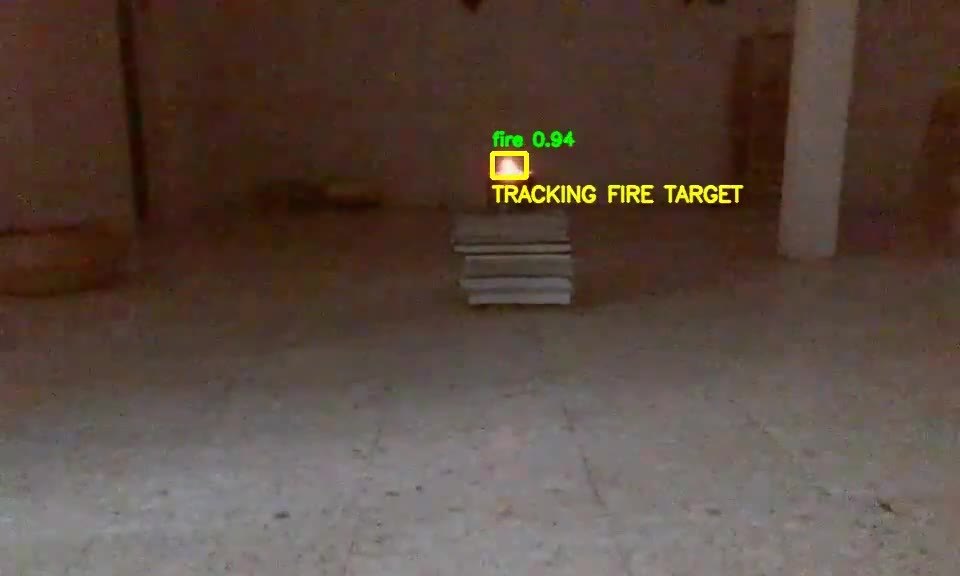
Real-time fire detection
A drone spots fire from its own camera and marks the evidence, and an agent decides the next move. All of it is open source.
- Live video from the on-board camera
- A fire-detection model on every frame
- An agent that picks the next command
- A dry-run mode before any flight
Follow the build on X
Flight tests, benchmark results and open-source releases, posted as they happen.